
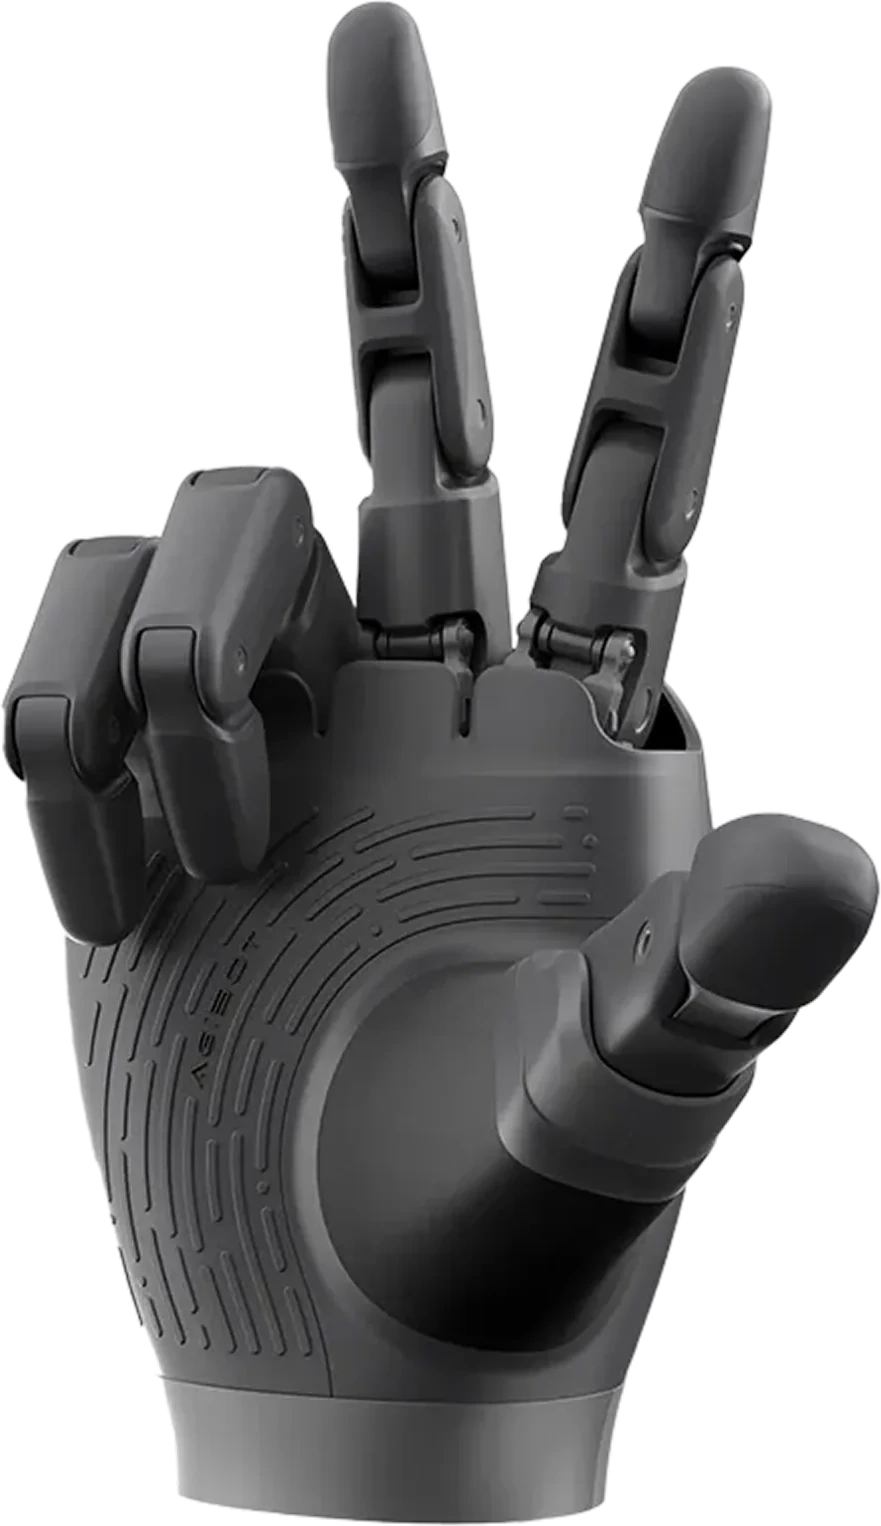
OmniHand Pro 2025 Dexterous robotic hand with 19 degrees of freedom
Five-finger end effector with 12 active joints and three-axis force sensing at the fingertips, for fine manipulation tasks with higher payload.
- Degrees of freedom19 (12 active)
- Grip force10 kg
- Weight≤ 810 g
- Tactile resolution0.1 N

RRP 12,500 €VAT not includedWith VAT (21%): 15,125 €
What is the OmniHand Pro 2025?
OmniHand Pro 2025 is a five-finger robotic hand with 19 degrees of freedom, 12 of them active, designed to be mounted as an end effector on humanoid robots and robotic arms. It integrates tactile sensors with three-axis force sensing at the fingertips and single-axis sensing in the palm, and offers a five-finger grip force of 10 kg.
More active joints
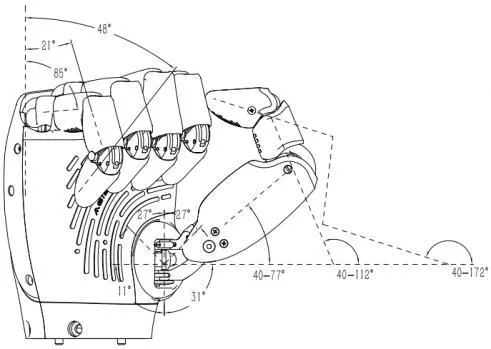
12 active degrees of freedom out of 19; the index and middle fingers offer up to 14° of abduction, and the thumb rotates up to 42°.
Three-axis touch sensing at the fingertips
Measures force on three axes at the fingertips and on one axis in the palm, with 0.1 N resolution and a range of 0 to 50 N.
Rugged construction
The sensors withstand up to 1,000 N without damage, and the hand operates between -20 and 50 °C.
Simple integration
12 to 24 V power supply, CAN-FD communication, and OTA updates.
Applications of the OmniHand Pro 2025
Scenarios where the OmniHand Pro 2025 fits in.
- End effector for humanoid robots
- Fine manipulation with fingertip force control
- Research in dexterous manipulation
- Integration into robotic arms and mobile manipulators
Technical specifications of the OmniHand Pro 2025
Weight
≤ 810 g
Dimensions
207 × 98 × 56 mm
Degrees of freedom
19
Active degrees of freedom
12
Minimum open/close time (typical)
0.7 s
Fingertip repeatability (typical)
0.4 mm
Five-finger grip force
10 kg
Operating voltage
12–24 V
Communication interface
CAN-FD
Operating temperature
-20 to 50 °C
Updates
OTA (remote)
Resolution
0.1 N
Sensing range
0–50 N
Maximum force without damage
1,000 N
Index · DIP (flexion/extension)
0° to 226°
View the full technical sheet
General
| Weight | ≤ 810 g |
|---|---|
| Dimensions | 207 × 98 × 56 mm |
| Degrees of freedom | 19 |
| Active degrees of freedom | 12 |
Performance
| Minimum open/close time (typical) | 0.7 s |
|---|---|
| Fingertip repeatability (typical) | 0.4 mm |
| Five-finger grip force | 10 kg |
Electronics and environment
| Operating voltage | 12–24 V |
|---|---|
| Communication interface | CAN-FD |
| Operating temperature | -20 to 50 °C |
| Updates | OTA (remote) |
Tactile sensors
| Force sensing | three-axis at the fingertips; single-axis in the palm |
|---|---|
| Resolution | 0.1 N |
| Sensing range | 0–50 N |
| Maximum force without damage | 1,000 N |
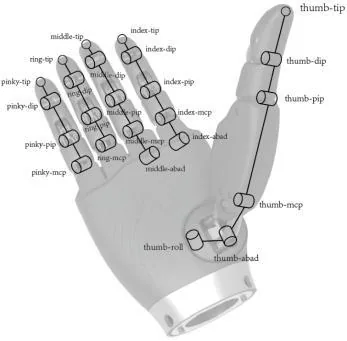
Joint range: index and middle fingers
| Index · DIP (flexion/extension) | 0° to 226° |
|---|---|
| Index · PIP (flexion/extension) | 0° to 157° |
| Index · MCP (flexion/extension) | 0° to 76° |
| Index · ABAD (abduction/adduction) | 0° to 14° |
| Middle · DIP (flexion/extension) | 0° to 227° |
| Middle · PIP (flexion/extension) | 0° to 159° |
| Middle · MCP (flexion/extension) | 0° to 77° |
| Middle · ABAD (abduction/adduction) | 0° to 14° |
Joint range: ring finger, little finger, and thumb
| Ring and little fingers · DIP (flexion/extension) | 0° to 228° |
|---|---|
| Ring and little fingers · PIP (flexion/extension) | 0° to 159° |
| Ring and little fingers · MCP (flexion/extension) | 0° to 85° |
| Ring and little fingers · ABAD (abduction/adduction) | 0° (no abduction) |
| Thumb · DIP (flexion/extension) | 40° to 172° |
| Thumb · PIP (flexion/extension) | 40° to 112° |
| Thumb · MCP (flexion/extension) | 40° to 77° |
| Thumb · ABAD (abduction/adduction) | 0° to 54° |
| Thumb · ROLL (rotation) | 0° to 42° |
Gallery of the OmniHand Pro 2025
Other models in the range
 Accessories
OmniHand
Dexterous robotic hand with 16 degrees of freedom
RRP 4,900 €VAT not includedWith VAT (21%): 5,929 €
 Accessories
OmniHand Tactile
Dexterous robotic hand with tactile sensors
RRP 5,750 €VAT not includedWith VAT (21%): 6,957.50 €
 Accessories
OmniPicker
Industrial gripper with touch sensing for embodied AI
RRP 875 €VAT not includedWith VAT (21%): 1,058.75 €
 AccessoriesPartial data
Batería extra D5W
Spare battery for the D5W quadruped
RRP 2,000 €VAT not includedWith VAT (21%): 2,420 €