
OmniPicker Industrial gripper with touch sensing for embodied AI
Two-finger end effector with 140 N of force and tactile sensors at the fingertips, built for manipulation data capture and continuous production work.
- Maximum force140 N
- Maximum stroke120 mm
- Maximum payload5 kg
- Weight600 g

RRP 875 €VAT not includedWith VAT (21%): 1,058.75 €
What is the OmniPicker?
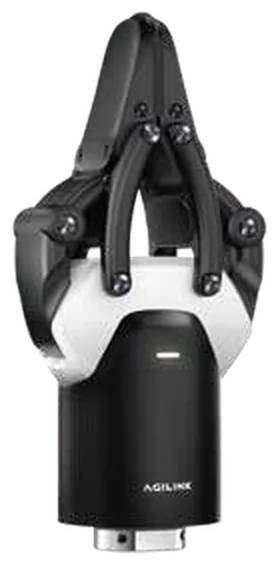
OmniPicker is a two-finger robotic gripper for robotic arms and humanoid robots. It combines 140 N of grip force, 120 mm of stroke, and tactile sensing at the fingertips with 0.1 N resolution. It is used in sorting and logistics, in data capture to train embodied AI systems, and in continuous production operations.
Industrial reliability
The 140 N grip force is validated over one million cycles at full load.
Adaptive grip with touch sensing
Tactile sensors on the gripping surface, with 0.1 N resolution, for handling standard parts, irregular shapes, and delicate objects with force control.
Built for data collection
Compatible with Dex-UMI and with an optional depth or fisheye camera, for capturing manipulation data and training models.
Open integration
CAN FD or RS485 communication, ROS 2, and an SDK in Python and C++.
Applications of the OmniPicker
Scenarios where the OmniPicker fits in.
- Pick-and-place in industrial sorting
- Parcel handling
- Warehouse automation
- Large-scale demonstration capture for embodied AI
- Force-based manipulation data collection
- Continuous operations in retail and e-commerce
Technical specifications of the OmniPicker
Weight
600 g
Maximum payload
5 kg
Maximum grip force
140 N
Maximum stroke
120 mm
Repeatability
±0.1 mm
Validated service life
1 million cycles at full load
Location
fingertips, on the gripping surface
Force resolution
0.1 N
Communication interface
CAN FD / RS485
Platforms
common robotic arms
Data collection
UMI (Dex-UMI)
Vision
optional depth or fisheye camera
Software
ROS 2, Python and C++ SDK
View the full technical sheet
General
| Weight | 600 g |
|---|---|
| Maximum payload | 5 kg |
Performance
| Maximum grip force | 140 N |
|---|---|
| Maximum stroke | 120 mm |
| Repeatability | ±0.1 mm |
| Validated service life | 1 million cycles at full load |
Tactile sensors
| Location | fingertips, on the gripping surface |
|---|---|
| Force resolution | 0.1 N |
Communication and integration
| Communication interface | CAN FD / RS485 |
|---|---|
| Platforms | common robotic arms |
| Data collection | UMI (Dex-UMI) |
| Vision | optional depth or fisheye camera |
| Software | ROS 2, Python and C++ SDK |
Gallery of the OmniPicker
Other models in the range
 Accessories
OmniHand
Dexterous robotic hand with 16 degrees of freedom
RRP 4,900 €VAT not includedWith VAT (21%): 5,929 €
 Accessories
OmniHand Tactile
Dexterous robotic hand with tactile sensors
RRP 5,750 €VAT not includedWith VAT (21%): 6,957.50 €
 Accessories
OmniHand Pro 2025
Dexterous robotic hand with 19 degrees of freedom
RRP 12,500 €VAT not includedWith VAT (21%): 15,125 €
 AccessoriesPartial data
Batería extra D5W
Spare battery for the D5W quadruped
RRP 2,000 €VAT not includedWith VAT (21%): 2,420 €