
OmniHand Dexterous robotic hand with 16 degrees of freedom
Compact, lightweight end effector for humanoid robots, mobile manipulators and research. Covers common gestures and grips with 10 active joints.
- Degrees of freedom16 (10 active)
- Weight≤ 550 g
- Grip force50 N
- Repeat accuracy0.3 mm

RRP 4,900 €VAT not includedWith VAT (21%): 5,929 €
What is the OmniHand?
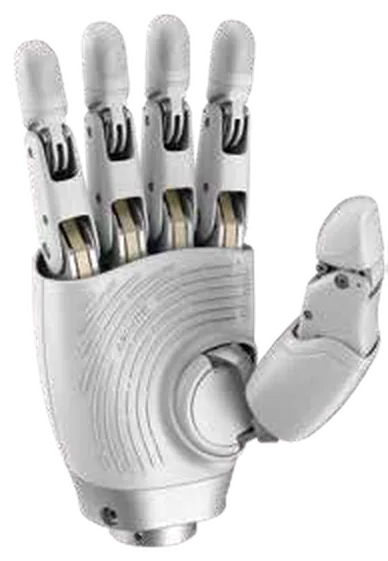
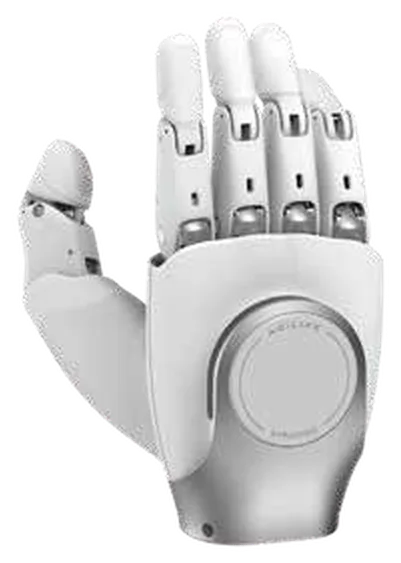
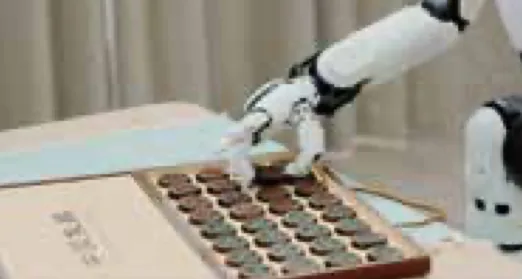
OmniHand is a five-finger robotic hand that mounts as an end effector on humanoid robots, robotic arms and mobile manipulators. It combines 16 degrees of freedom, 10 of them active, in 180 × 85 × 38.5 mm and around 550 g. It is designed for interaction with people, service robotics, teaching and research.
Built for large-scale deployment
Compact, lightweight format, designed to integrate into common humanoid robots and mobile manipulators.
10 active joints and 6 passive joints
Covers common gestures and most grip types, enabling collaboration with people beyond simply picking up objects.
Fast response
Opens and closes in 0.5 s and repeats fingertip position with a typical accuracy of 0.3 mm.
Open integration
CAN-FD or RS485 communication, compatibility with Dex-UMI and ROS 2, Python and C++ SDK, and OTA updates.
Applications of the OmniHand
Scenarios where the OmniHand fits in.
- Human-robot interaction: gestures, service tasks and collaboration
- Training and development of teaching content on manipulation
- Prototyping in academic research projects
- Mobile and service robotics: light grip for delivery, hospitality and assistance
- End effector for humanoid robots
- End effector for mobile manipulators
Technical specifications of the OmniHand
Weight (without wrist cover or screws)
≤ 550 g
Dimensions
180 × 85 × 38.5 mm
Degrees of freedom
16
Active degrees of freedom
10
Passive degrees of freedom
6
Minimum open / close time (typical)
0.5 s / 0.5 s
Fingertip repeat accuracy (typical)
0.3 mm
Five-finger grip force
50 N
Payload (commercial presentation)
2 kg in stable grip; 5 kg lifting
Operating voltage
18–27 V
Communication interface
CAN-FD / RS485
Operating temperature
-10 to 45 °C
Tactile sensors
not included (available on OmniHand Tactile)
Index-to-pinky fingers · DIP (flexion/extension)
0° to 171°
Index-to-pinky fingers · PIP (flexion/extension)
0° to 80°
View the full technical sheet
General
| Weight (without wrist cover or screws) | ≤ 550 g |
|---|---|
| Dimensions | 180 × 85 × 38.5 mm |
| Degrees of freedom | 16 |
| Active degrees of freedom | 10 |
| Passive degrees of freedom | 6 |
Performance
| Minimum open / close time (typical) | 0.5 s / 0.5 s |
|---|---|
| Fingertip repeat accuracy (typical) | 0.3 mm |
| Five-finger grip force | 50 N |
| Payload (commercial presentation) | 2 kg in stable grip; 5 kg lifting |
Electronics and environment
| Operating voltage | 18–27 V |
|---|---|
| Communication interface | CAN-FD / RS485 |
| Operating temperature | -10 to 45 °C |
| Tactile sensors | not included (available on OmniHand Tactile) |
Joint range
| Index-to-pinky fingers · DIP (flexion/extension) | 0° to 171° |
|---|---|
| Index-to-pinky fingers · PIP (flexion/extension) | 0° to 80° |
| Index-to-pinky fingers · ABAD (abduction/adduction) | 0° to 10° |
| Thumb · DIP (flexion/extension) | 0° to 160° |
| Thumb · PIP (flexion/extension) | 0° to 106° |
| Thumb · MCP (flexion/extension) | 0° to 45° |
| Thumb · ABAD (abduction/adduction) | 0° to 90° |
| Thumb · ROLL (rotation) | 0° to 60° |
Compatibility and integration
| Platforms | common humanoid robots and robotic arms |
|---|---|
| Data collection | Dex-UMI |
| Software | ROS 2, Python and C++ SDK |
| Updates | OTA (remote) |
Gallery of the OmniHand
Other models in the range
 Accessories
OmniHand Tactile
Dexterous robotic hand with tactile sensors
RRP 5,750 €VAT not includedWith VAT (21%): 6,957.50 €
 Accessories
OmniHand Pro 2025
Dexterous robotic hand with 19 degrees of freedom
RRP 12,500 €VAT not includedWith VAT (21%): 15,125 €
 Accessories
OmniPicker
Industrial gripper with touch sensing for embodied AI
RRP 875 €VAT not includedWith VAT (21%): 1,058.75 €
 AccessoriesPartial data
Batería extra D5W
Spare battery for the D5W quadruped
RRP 2,000 €VAT not includedWith VAT (21%): 2,420 €